Bayes and Particle Filters
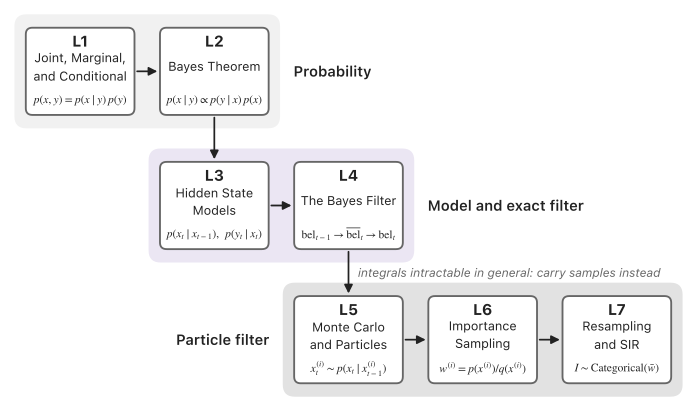
Bayes filter의 두 식과 SIR particle filter의 loop를 외우지 않고 읽기 위한 일곱 강의. L1–L2는 확률 규칙, L3–L4는 hidden state model과 exact Bayes filter, L5–L7은 particle 근사.
Study notes compiled from my research wiki. Series are read in order, course notes follow the lecturer, and a paper gets a prerequisites note before the paper itself.
Bayes filter의 두 식과 SIR particle filter의 loop를 외우지 않고 읽기 위한 일곱 강의. L1–L2는 확률 규칙, L3–L4는 hidden state model과 exact Bayes filter, L5–L7은 particle 근사.
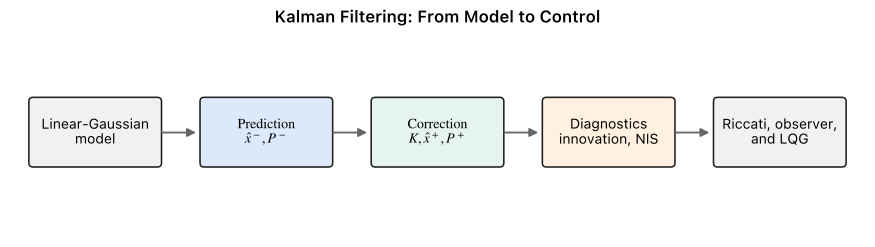
Linear-Gaussian estimation의 prediction과 correction을 유도하고, implementation·noise diagnostics·steady-state Riccati·LQG까지 연결하는 일곱 강의.
UCL, 2015. Lecture notes that say only what the slides don't, question lists from my own reading, and a Korean reading companion for lecture 6. Slides are shown under CC BY-NC 4.0.
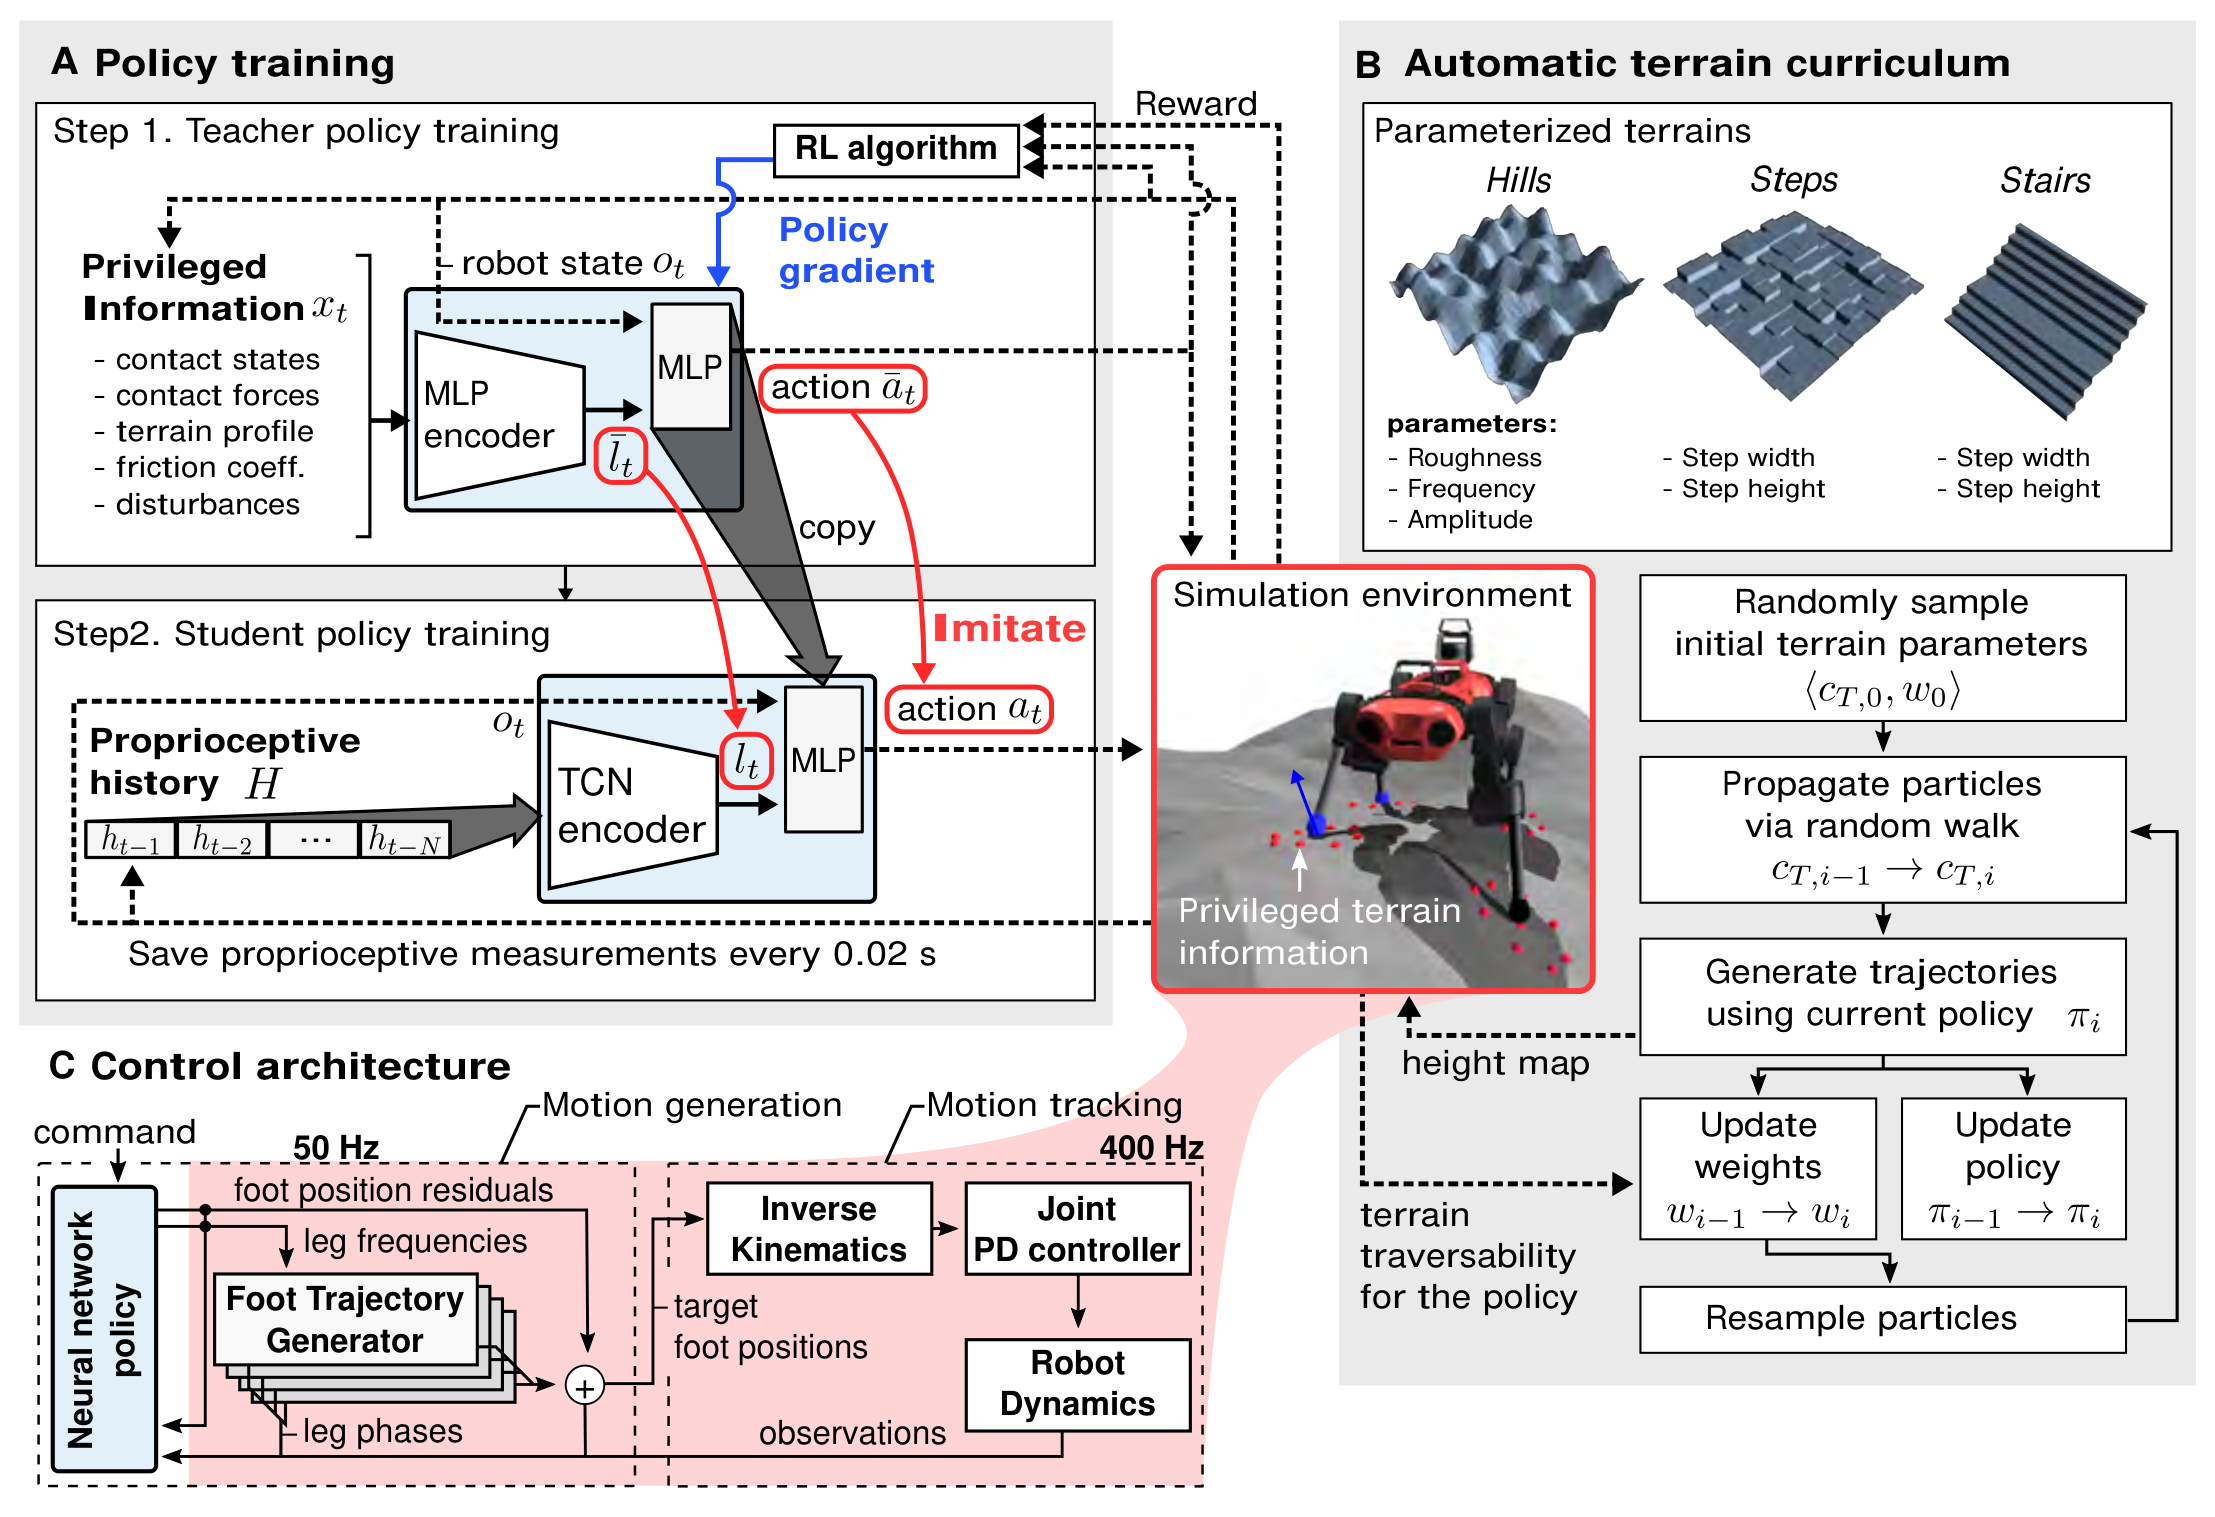
What Learning Quadrupedal Locomotion over Challenging Terrain assumes you already know: the motion prior, TRPO, privileged learning and DAgger, TCN memory, and the Bayes-to-particle curriculum.
What each note assumes and what it leads to. Follow the arrows; dashed nodes are lectures still to be written.
PublishedPlannedElsewhere on the web