Jul 2026
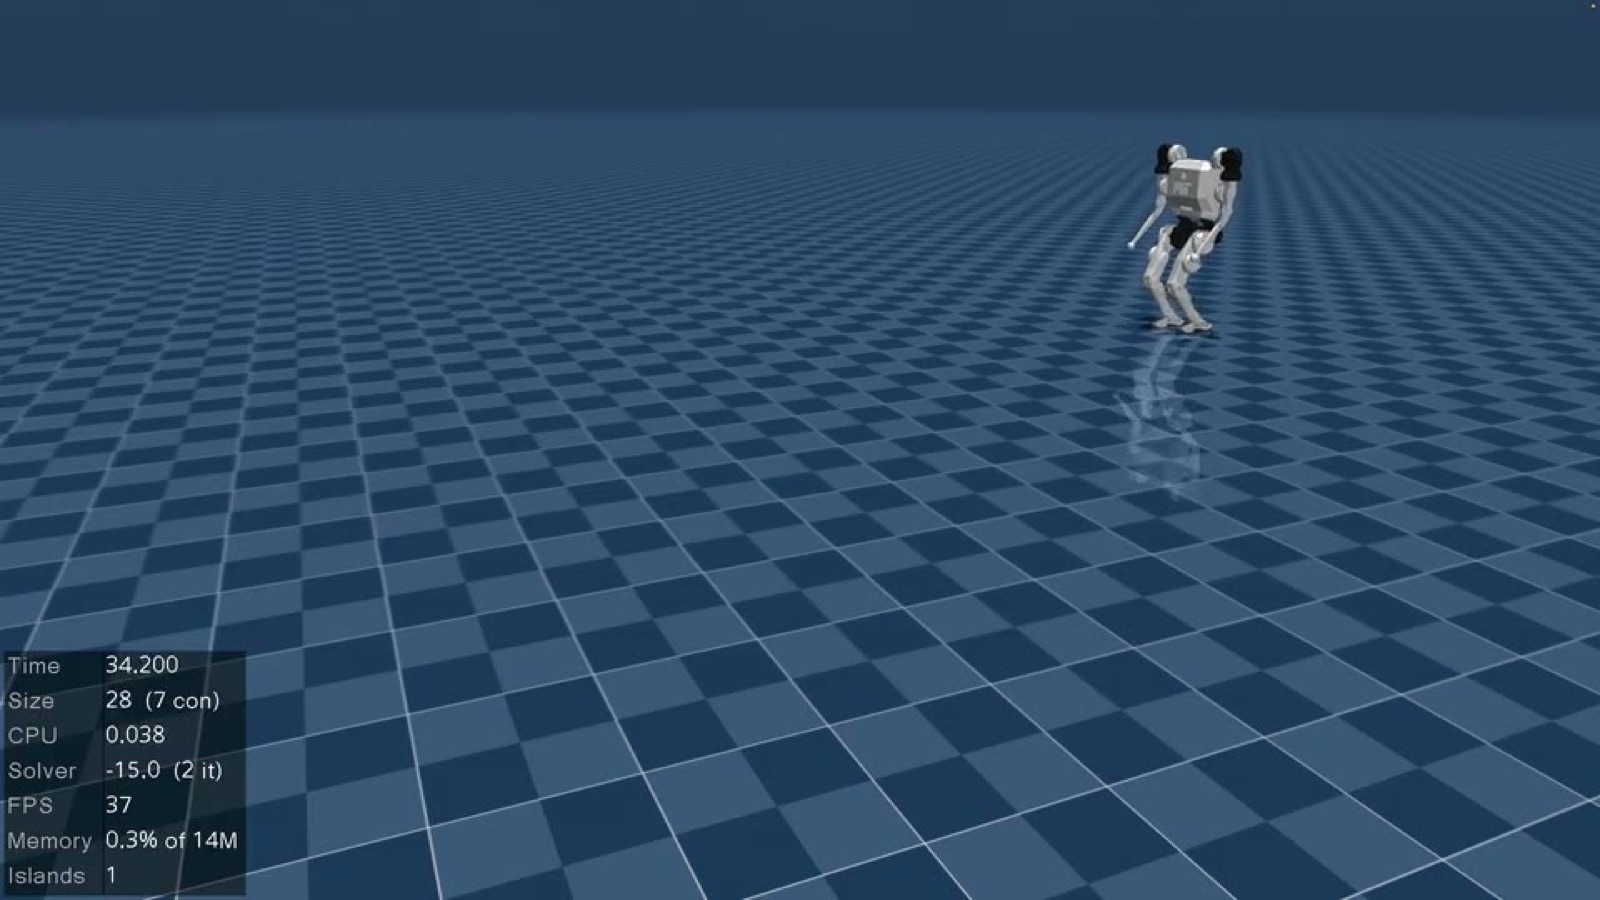
Convex MPC for Bipedal Humanoid Locomotion
Extending the MIT Cheetah 3 convex MPC to CoP-constrained humanoid walking. Single-rigid-body modeling, 6D contact-wrench optimization, swing-foot planning, and a reproducible MPC debugging workflow, built from scratch in C++ on MuJoCo. C++17 · MuJoCo · Eigen · OSQP